
SENIOR SOFTWARE ENGINEER - PERCEPTION & SENSOR FUSION (DEEP LEARNING)
Responsibilities
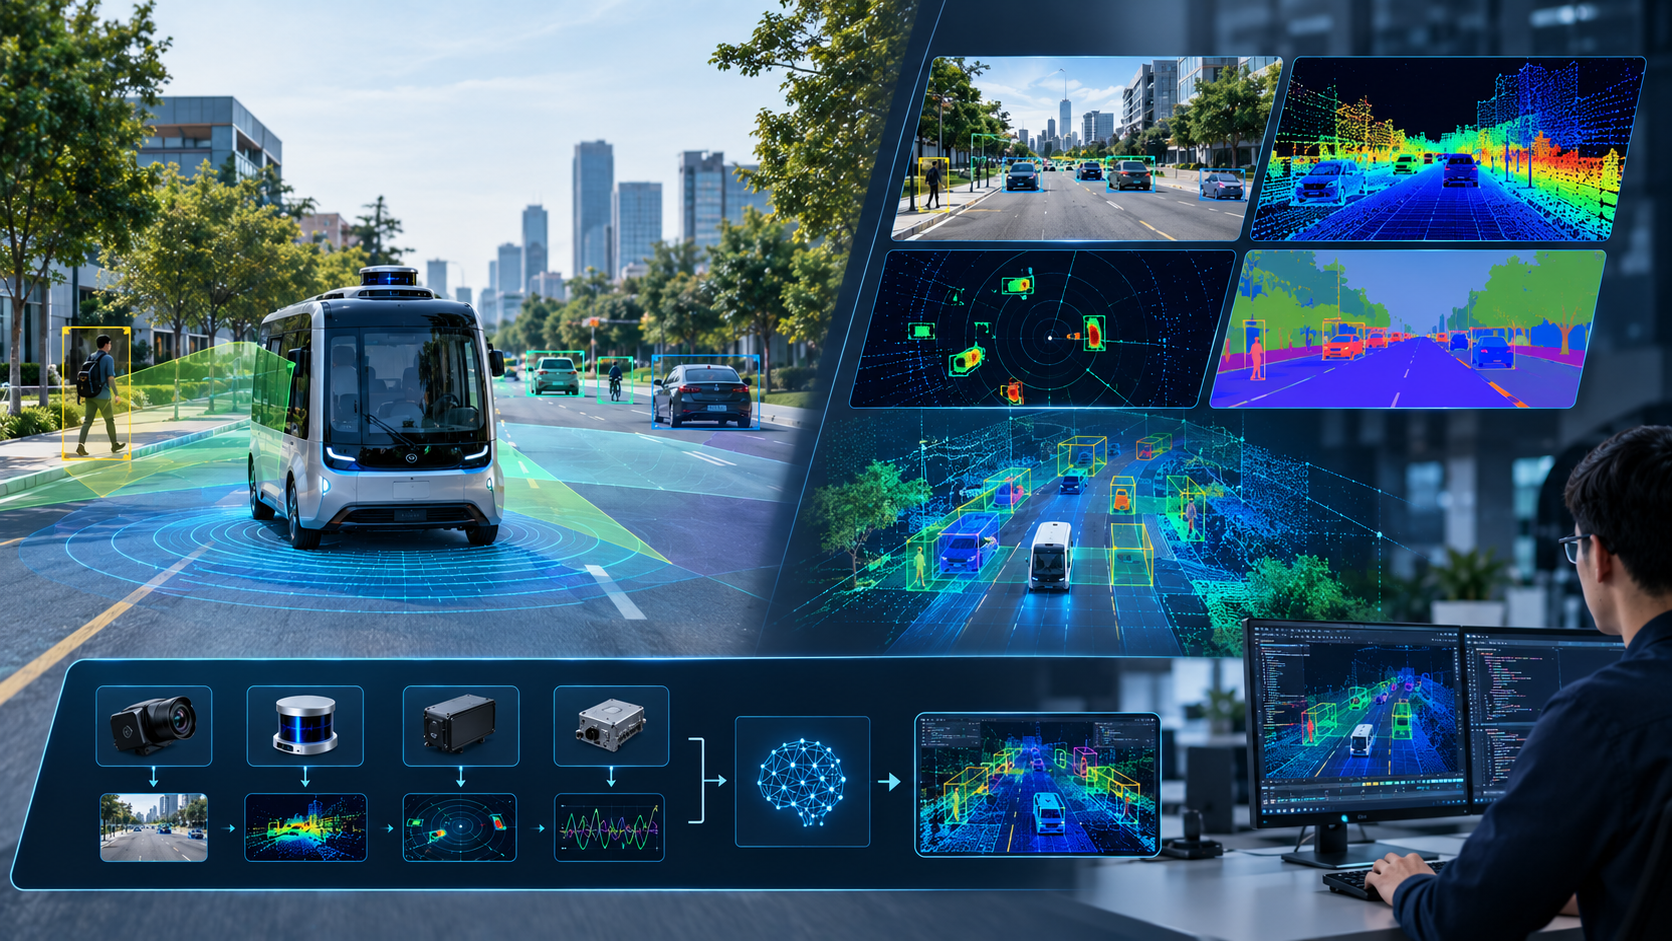
- Develop perception algorithms for object detection, tracking, classification, and segmentation using deep learning.
- Design and maintain multi-sensor fusion pipelines (LiDAR, camera, GPS/IMU, Radar) time synchronization, calibration, and coordinate-frame transforms.
- Train, validate, and fine-tune AI/ML models to meet performance, accuracy, and reliability requirements
- Develop algorithms and optimise for LiDAR and Camera sensor data processing, including tracking filters (e.g., Kalman filters, particle filters), feature extraction, object detection, and sensor fusion techniques
- Integrate trained models into the production system, ensuring smooth deployment and operation under production-grade ROS (1/2) nodes in C++.
- Take models from research to deployment - TensorRT conversion, quantization, and latency/throughput optimization on NVIDIA embedded platforms.
- Build and maintain offline replay/validation tooling against recorded sensor data.
- Collaborate with cross-functional teams (data engineering, software, hardware) to ensure end-to-end system integration
- Maintain documentation of AI models, pipelines, and integration processes for maintainability and scalability
- Stay updated on relevant AI/ML advancements and recommend improvements to existing systems
Requirements
- Degree, Master's or PhD in Computer Science, Engineering, or a related field (or equivalent industry experience).
- Strong C/C++ and object-oriented design skills on Linux, plus Python for tooling.
- Working knowledge of LiDAR/camera geometry: calibration, projection, plane fitting, point-cloud registration.
- ROS (1 and 2) experience.
- 3+ years with a deep-learning stack such as OpenCV, TensorFlow, Tensor RT, PyTorch, or Caffe.
- 5+ years of Linux system development.
- 3+ years on robotic/autonomous/ADAS systems, with Camera and/or LiDAR and/or Radar development.
- Proficient with Git, Docker, and CI/CD pipelines.
- Self-motivated, able to own ambiguous problems end-to-end with minimal supervision.
Nice to have
- Experience with foundation/promptable segmentation models.
- Experience with Open3D, PCL, or similar point-cloud libraries.
- Experience with geospatial/GIS data (GPS alignment, routing APIs).
- Experience building 3D reconstructions or maps from sensor data.